Posts

Showing posts with the label servo

Robotic Arm with Computer Vision
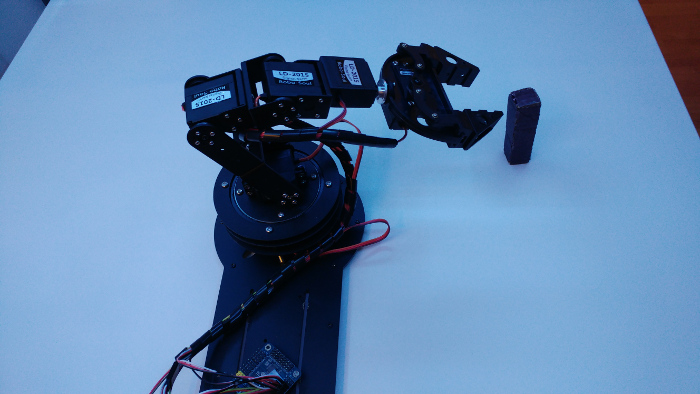
Image
Robotic Arm with Computer Vision - Picking Up the Object Idea The main idea behind this project was to create an environment where a robotic arm can execute various commands based on image analysis of a scene. In this article, I will describe each part of the project in detail. For the first task, I focused on detecting and moving a single object. Environment The setup consists of several components assembled together. I used an old table as the base, repainting it white to provide better contrast with the objects. The robotic arm, which I purchased from eBay, is mounted on the middle of the longer side of the table. The arm has six servo motors, including a rotating base and claws at the other end. The parts are made of aluminum and are quite sturdy. Next, I cut and mounted perforated metal ledges to the corners of the table, securing everything together. I then attached an RGB LED strip to the bottom side of the top part of the structure. Finally, I placed a USB ca...

Self playable game on smartphone

Image
Hardware I recently assembled a Lego phone holder that rotates along the Y-axis (the longer side of the phone). The holder's end is attached to a servo motor, which is connected to an Android smartphone via USB OTG through a motor module. This motor module can control up to 24 servo motors and operates at 5 volts. Software The motor module has its own built-in protocol, which handles rotation and speed, with parameters separated by newline characters. The second part of the project involved developing an Android application to communicate with the servo module using this serial protocol. I based the application on an example of USB serial communication with Arduino, adapting it to work with my device. Game For this project, I chose a game I developed about a year ago. It's a simple game where the accelerometer controls a rocket that must navigate through gates. Tilting the device left or right adjusts the rocket's position, and the goal is to pass through as many gates as p...